Standalone JIT
Compiling a hand-written NumPy function to native Rust, and getting its exact Jacobian with it.
What the JIT does
FastSim traces a Python function once, records the operations it performs, and lowers them to the scalar SSA form the engine uses internally. From then on the function runs as native Rust — the Python callable is not touched again.
Blocks that take a custom function do this automatically. fastsim.jit is the same machinery on its own, for any function MATHINLINE0ENDMATH:
jit(f)— the traced function, callable like the original.jacobian(f)— the exact MATHINLINE1ENDMATH, differentiated from the recorded operations rather than approximated by finite differences.
Because the traced form is IR, a model built on such a function is not stuck in Python: it lowers to C and exports to an FMU like any native block.
jit() and jacobian() produce the same IR that Simulation.to_c() and Simulation.to_fmu() consume.
The Function
The Robertson kinetics problem — three species, rate constants nine orders of magnitude apart:
MATHDISPLAY0ENDMATH
with MATHINLINE1ENDMATH, MATHINLINE2ENDMATH, MATHINLINE3ENDMATH.
System Parameters
The Right-Hand Side
Written by hand, in the way you would write it anyway.
Compiling It
jit returns a callable with the same signature. The trace happens on the first call, or eagerly if you pass n_x.
python: [-0.014   -0.00052  0.01452]
jit   : [-0.014   -0.00052  0.01452]
The tape is specialised to the length it was traced with. A call with a different length re-traces:
28.0
3.0
Jacobians
jacobian differentiates the traced operations, so one pass yields the whole matrix — no step size to pick, and no extra evaluations of MATHINLINE0ENDMATH.
[[-4.00e-02  1.00e+03  2.20e-01]
 [ 4.00e-02 -2.32e+03 -2.20e-01]
 [ 0.00e+00  1.32e+03  0.00e+00]]
Verification
The Robertson Jacobian can be written down by hand:
MATHDISPLAY0ENDMATH
worst difference from the analytic Jacobian: 0.000e+00
Using It in a Model
The same function as the right-hand side of an ODE block. Robertson is stiff, so it wants an implicit solver — GEAR52A here.
Results
Species 2 stays six orders of magnitude below the others, so it is scaled up to be visible at all — the usual way this solution is plotted.
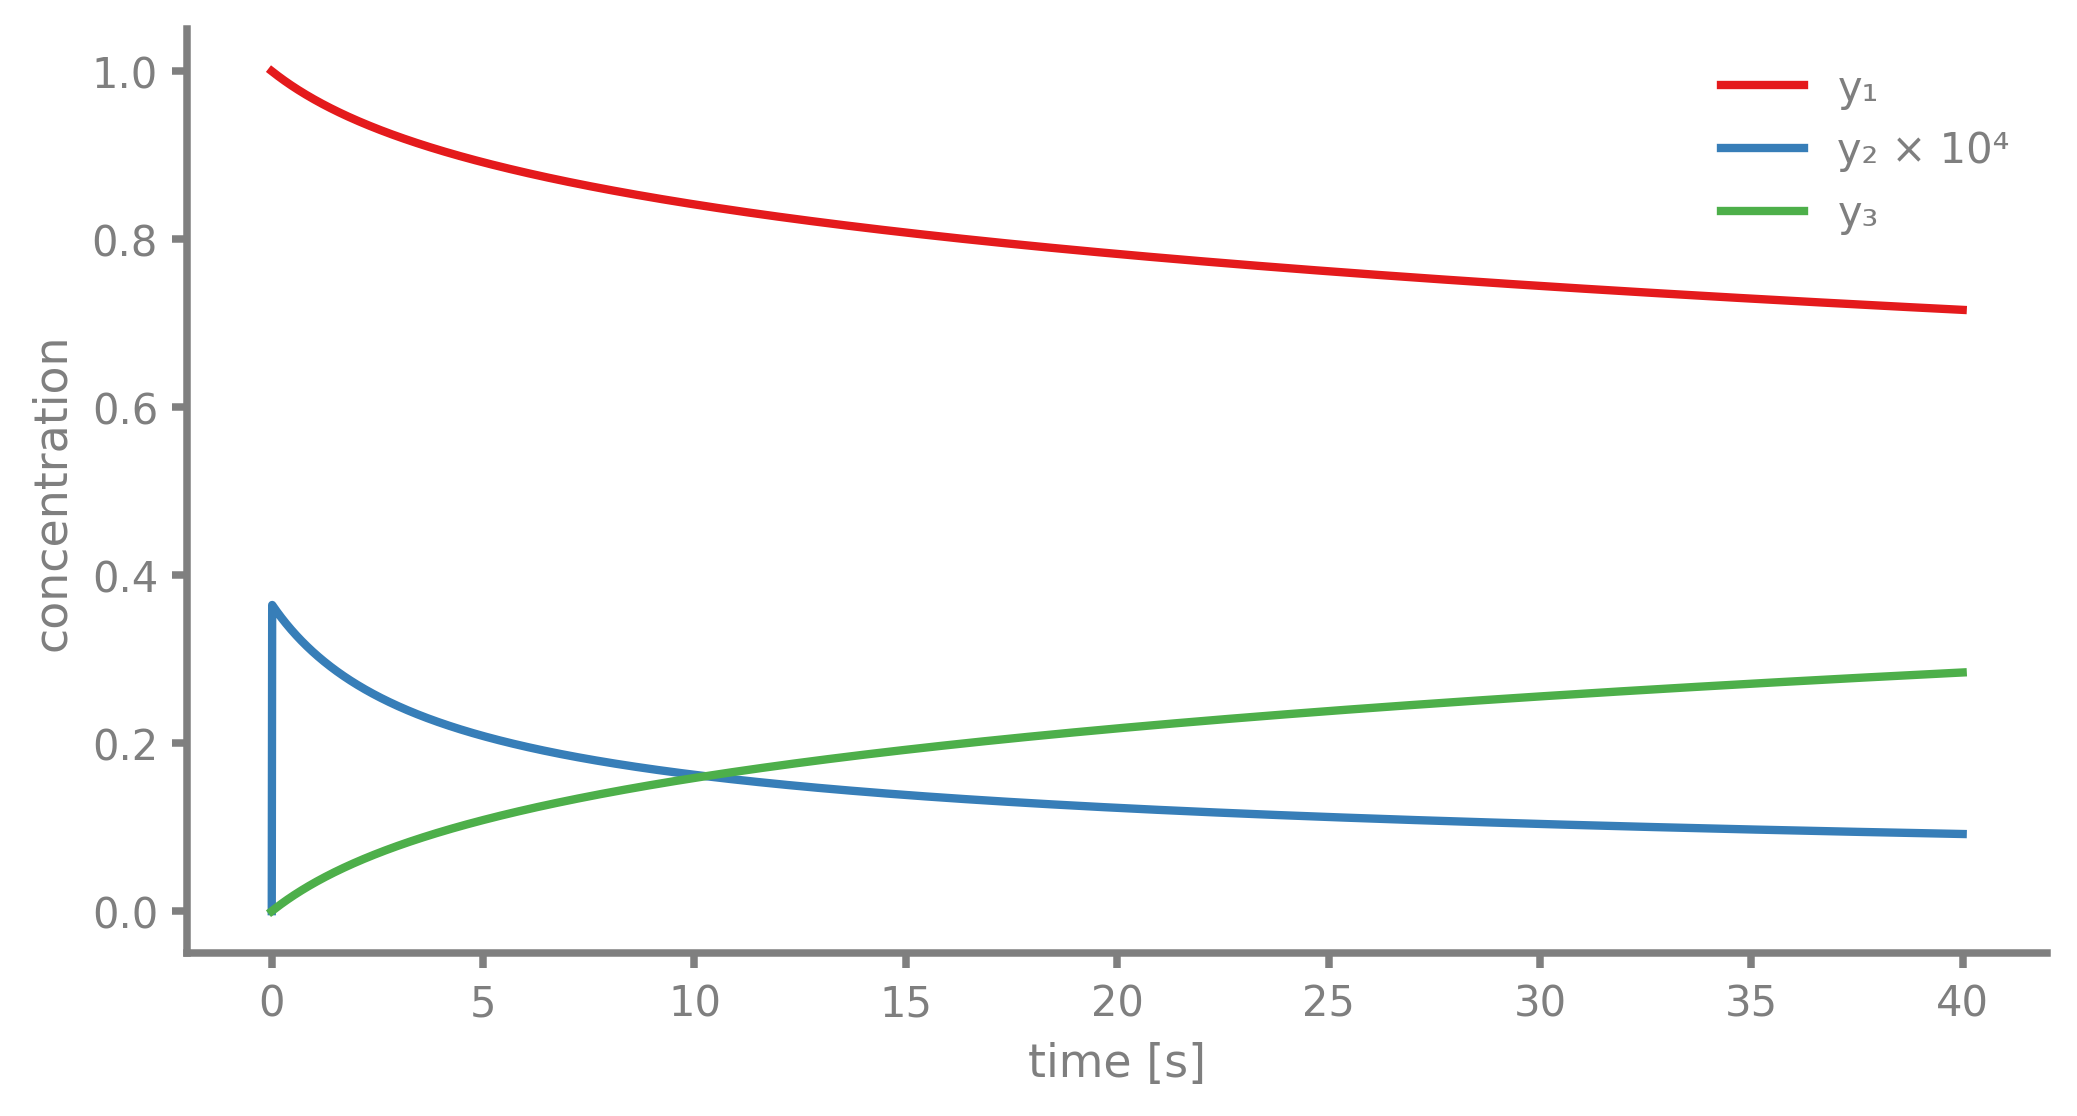
Mass is conserved, which is the easiest thing to check on this system: MATHINLINE0ENDMATH for all time.
worst deviation from unit mass: 4.469e-10
What Traces
Everything the tracer sees has to be an operation on the values, not a decision about them. When it cannot trace something it says so, and says what to write instead.
  arithmetic       traced
  np.where         traced
  np.sin / np.exp  traced
  np.linalg.norm   traced
  matrix product   traced
  np.clip          traced
  python if        JitTracer cannot be used in if/else during JIT tracing
  float() cast     JitTracer cannot be converted to float during tracing
A Python if on a traced value is the one people hit first. Rewrite it as np.where and it traces.